Dexterity & Movement
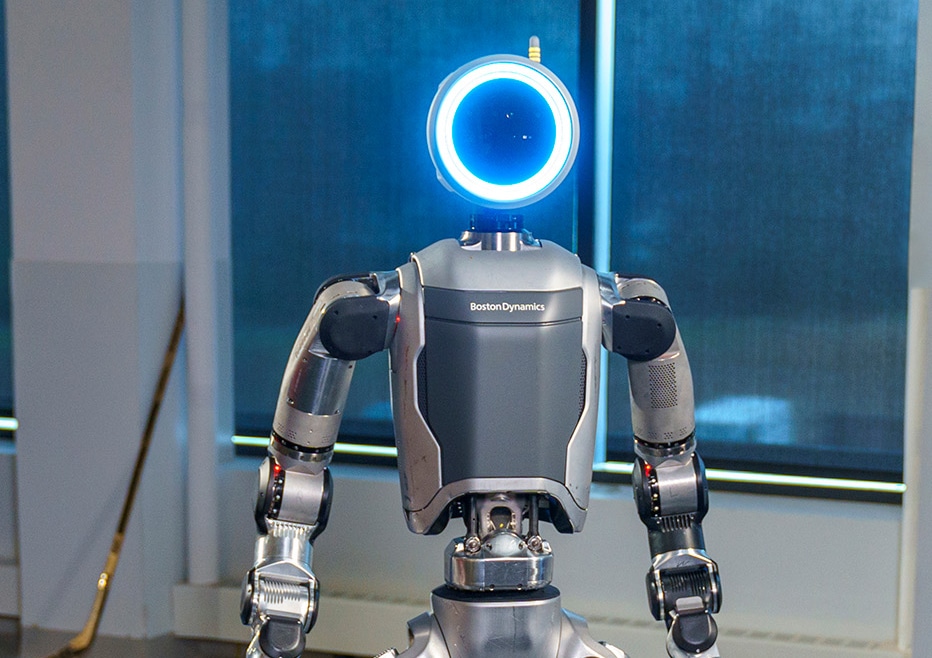
Atlas' industrial ambitions make walking a whole-job problem
Mobility matters because a robot must reach, carry and recover in spaces designed for people. The decisive test is the task completed at the end of the walk.
Manipulation, mobility and recovery in the physical world.
Atlas' industrial ambitions make walking a whole-job problem ↗Mobility matters because a robot must reach, carry and recover in spaces designed for people. The decisive test is the task completed at the end of the walk.
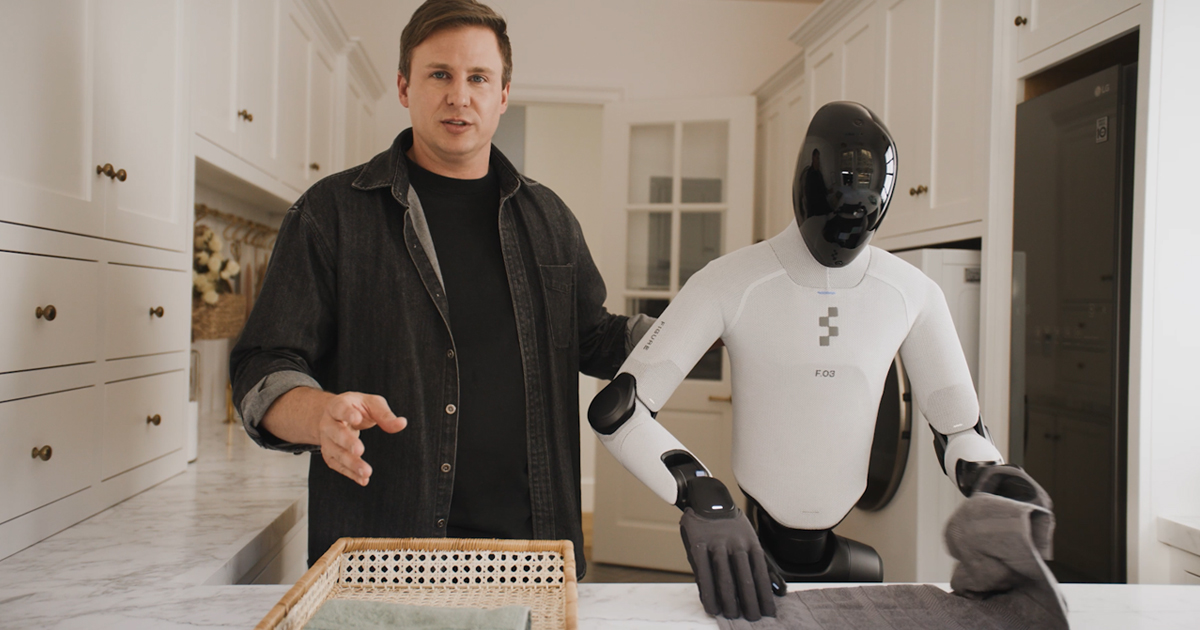
Figure's September 2026 evaluation reports whole-body work in unfamiliar homes. Its most revealing question is how the robot responds when the first attempt is imperfect.
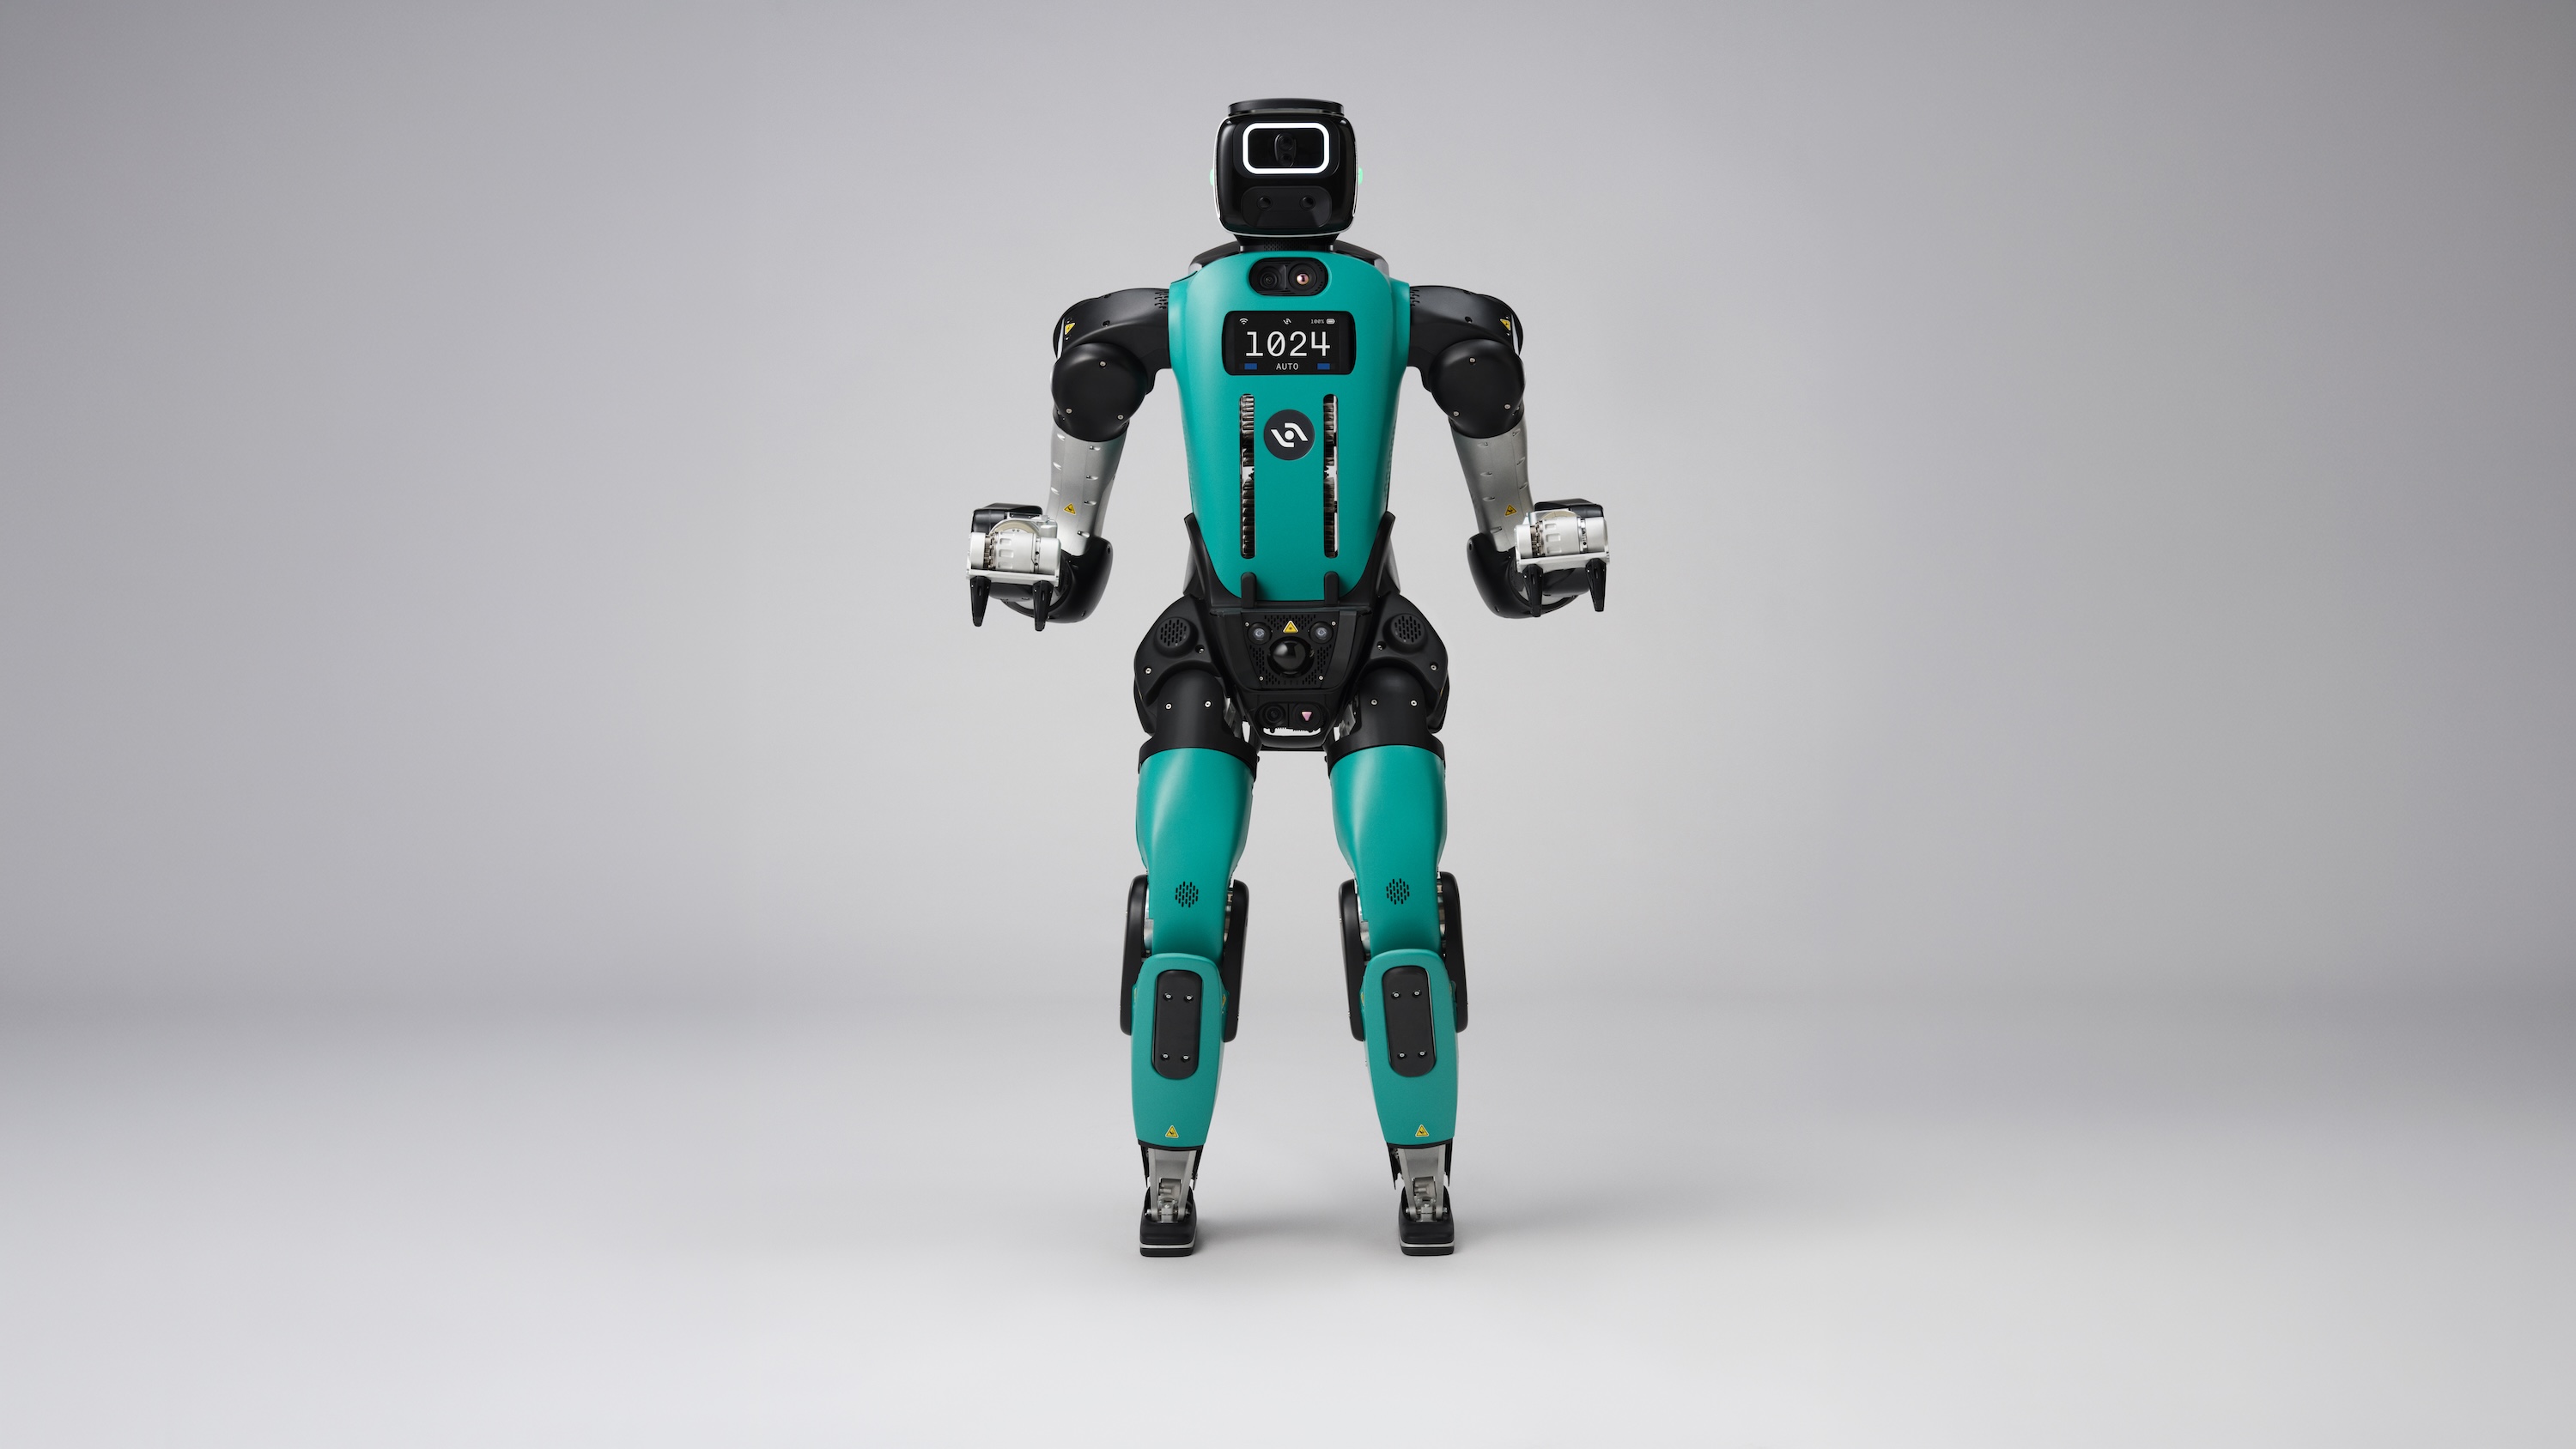
Agility's new architecture includes people detection, independent motion oversight and a seated response. The safety case still belongs to the complete application.